Which Construction Tasks Can Robots Take On?
Match automation to repeatability, changing conditions and human intervention.
By Edward Kim | BuildNextSphere
Source: AI-generated concept illustration; layout and editorial direction by Edward Kim | BuildNextSphere.
Note: Hypothetical scene; not Edward’s project, a product demonstration or measured performance evidence.
A robot can drill a ceiling, mark a floor or tie rebar. That answers a capability question. It does not yet answer whether deployment will help this workfront. A machine may complete a repeated operation quickly while the team spends longer preparing the area, moving it between rooms or waiting for another trade.
My starting view is that repetition matters together with volume and continuity. Where conditions change frequently or work comes in small fragments, deploying a robot can add more effort than it removes. This article develops that view as a question to test—not as a result from my own robot deployment.
1. Identify the Physical Task First
Source: AI-generated concept illustration; layout and editorial direction by Edward Kim | BuildNextSphere.
Note: Hypothetical scene; not Edward’s project, a product demonstration or measured performance evidence.
Public supplier descriptions already show several bounded uses. Hilti describes Jaibot as a semi-autonomous ceiling-drilling system: an operator navigates it, while drilling within reach is automated using planned data. Dusty’s FieldPrinter transfers digital layout information onto the floor. Advanced Construction Robotics describes TyBOT’s automated tying of horizontal rebar intersections. Brokk supplies remotely controlled demolition robots. These are different tasks and different arrangements of human control. [S1–S4]
A tying robot does not install every bar; a layout robot does not construct the wall it marks. Remote control, automatic operation and autonomous functions are not a compulsory ladder that every project must climb. Define the work boundary, inputs and remaining human work before comparing alternatives. Supplier descriptions establish reported functions here, not independently verified project-wide savings.
2. Why a Construction Site Is Hard to Repeat
Source: AI-generated concept illustration; layout and editorial direction by Edward Kim | BuildNextSphere.
Note: Hypothetical scene; not Edward’s project, a product demonstration or measured performance evidence.
The same task name can hide very different working conditions. A floor may be open today and divided by partitions tomorrow. Material storage, access routes, completed services and neighbouring trades can change the space available. Repeating a drilling pattern is not the same as repeatedly receiving a clear, accessible and correctly prepared work area.
For a real example of the surrounding coordination burden, Dusty’s deployment guidance discusses planning with site teams and other trades. Its guidance is specific to that system; the broader editorial question is whether the intended robot will receive a usable workfront at the needed time. If it must repeatedly stop, relocate or be checked against changed conditions, a faster individual motion may not move the following trade forward. [S5]
3. Compare the Whole Task, Not Only the Cycle
Source: AI-generated concept illustration; layout and editorial direction by Edward Kim | BuildNextSphere.
Note: Hypothetical scene; not Edward’s project, a product demonstration or measured performance evidence.
Consider a hypothetical ceiling-drilling comparison. In Area A, a large clear floor offers many similar planned holes and a continuous work window. In Area B, a smaller number of holes is scattered across rooms, with changing access and overlapping services. The same type of robot could face very different preparation and relocation demands. Neither area is an actual measured project in this article.
Compare preparation, positioning and verification, the operation itself, moves, waiting, inspection and correction. Record support labour separately from elapsed time, since several activities may overlap. Training and maintenance also belong in the account. If added setup and interruption exceed the operation time saved, the overall task may take longer. This is a conditional comparison, not a universal break-even formula or an argument against robotics.
4. Consider Access and Exposure, Not Speed Alone
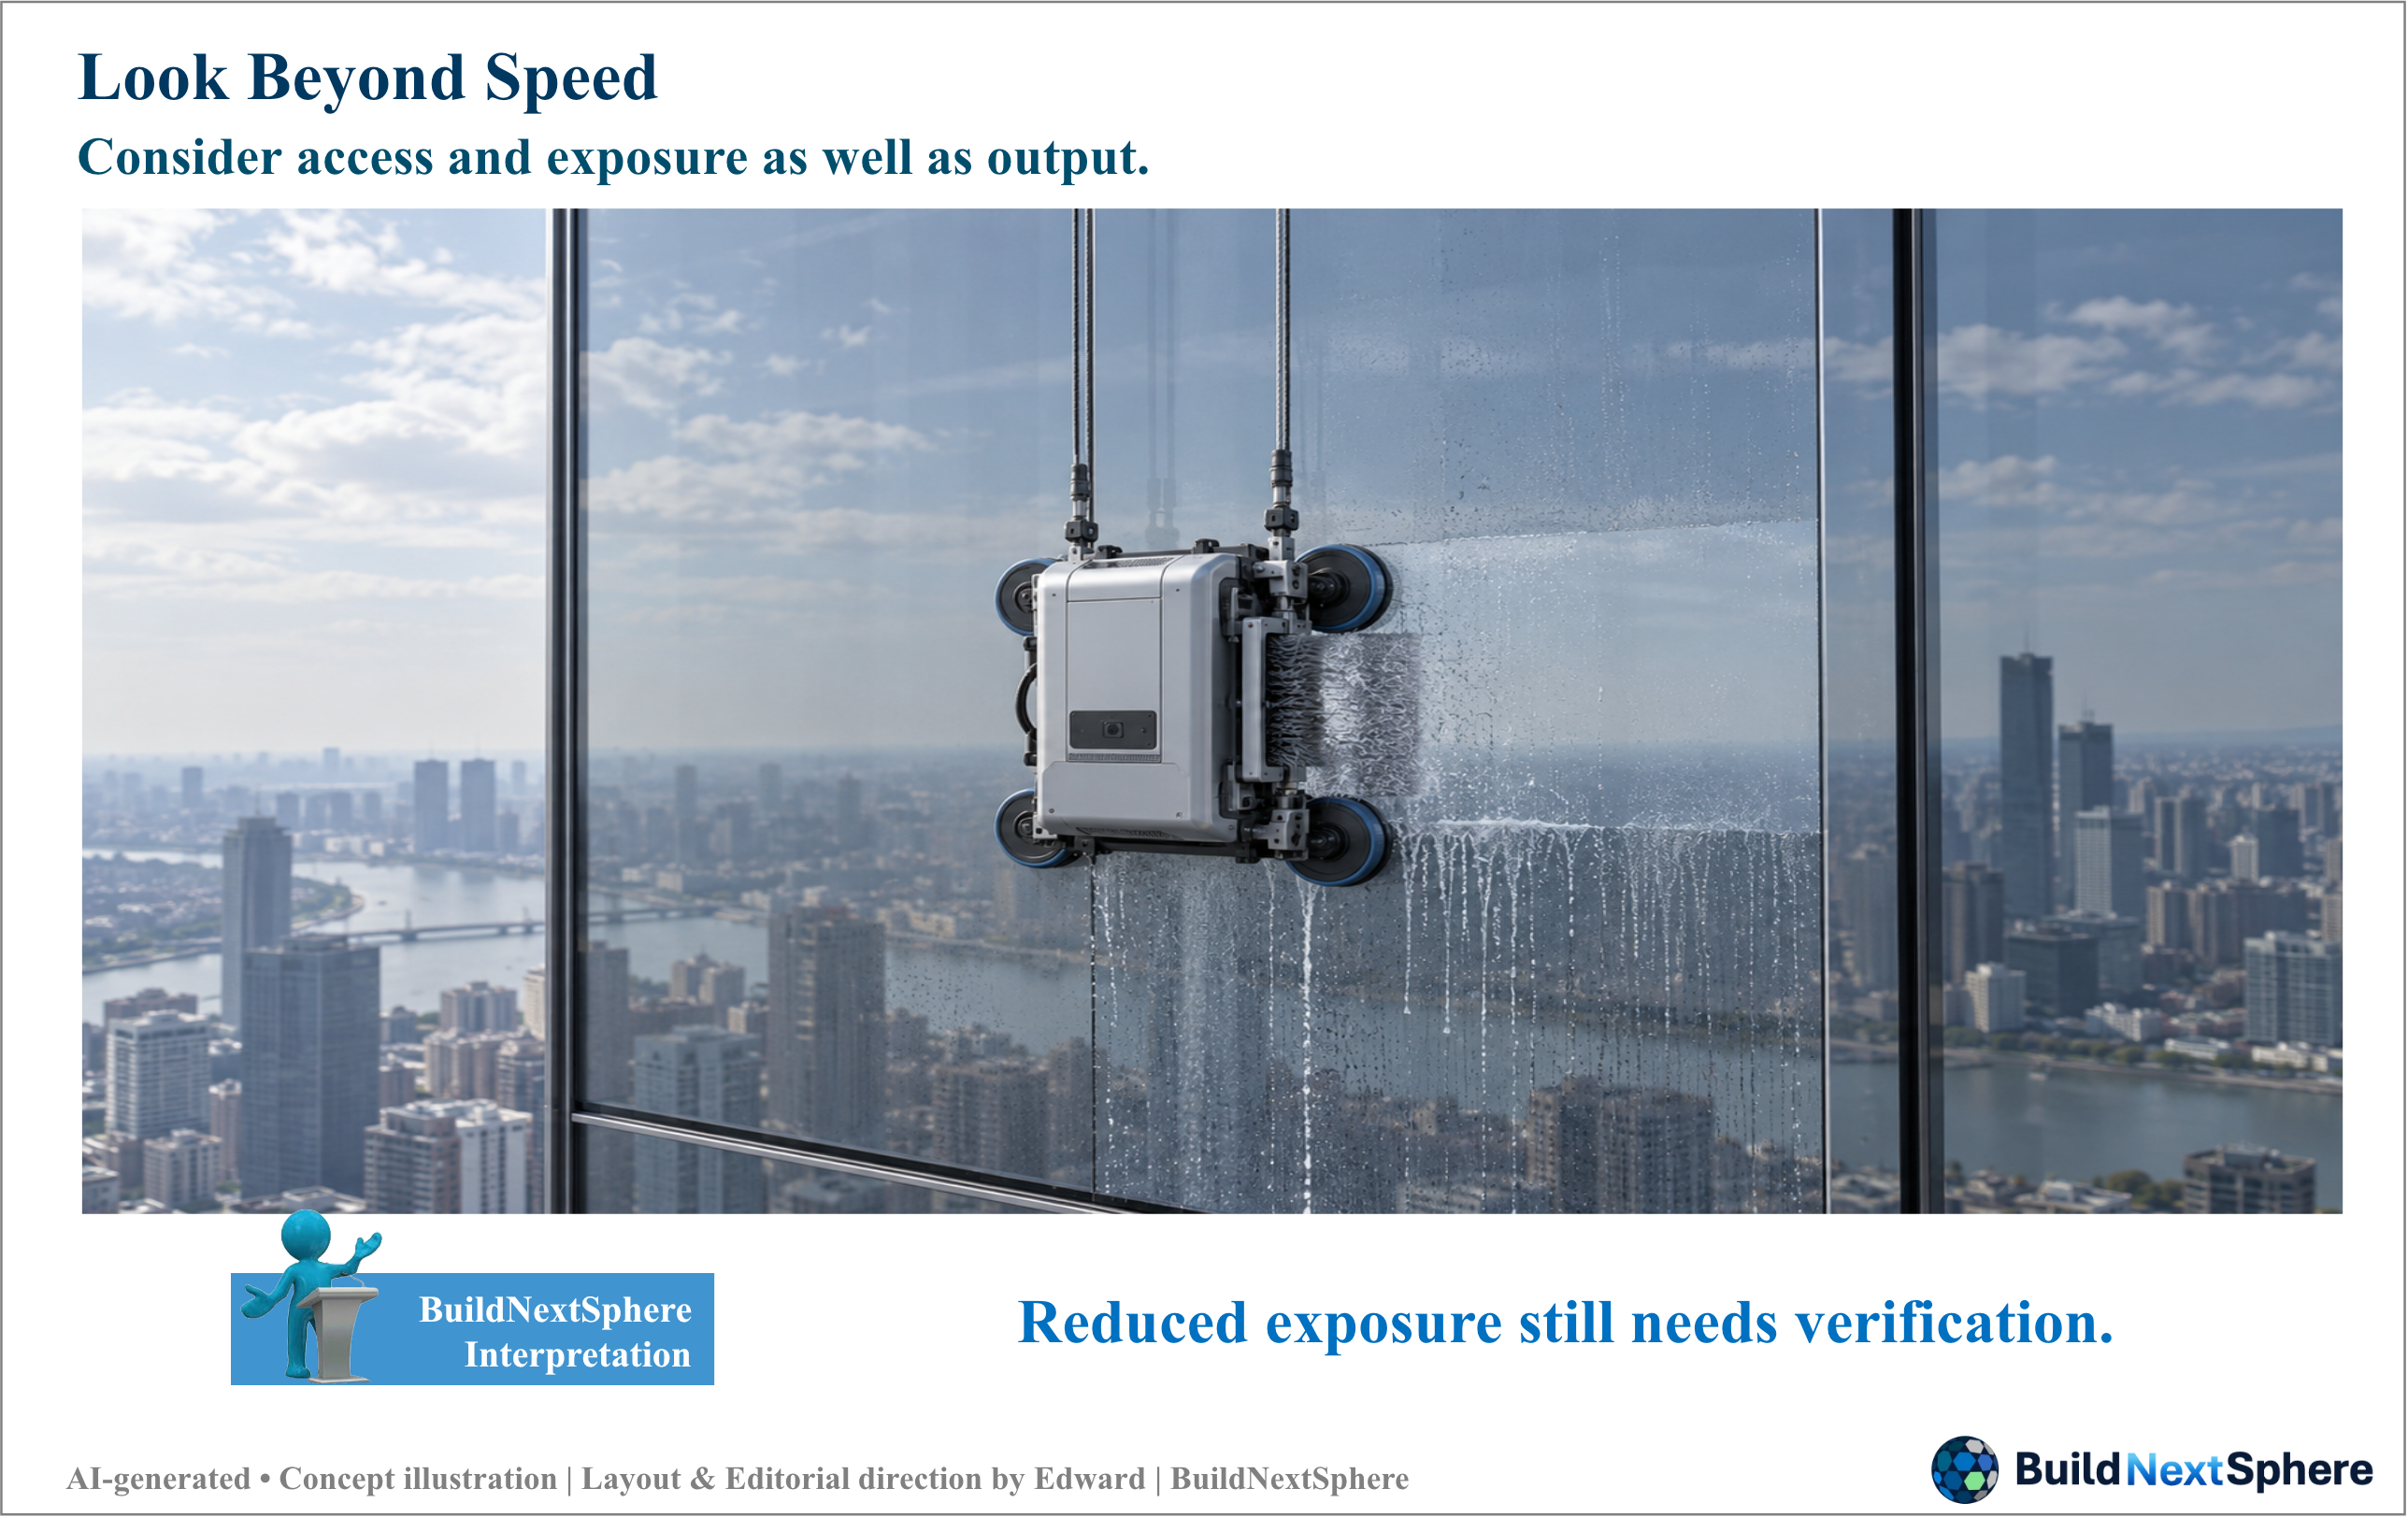
Source: AI-generated concept illustration; layout and editorial direction by Edward Kim | BuildNextSphere.
Note: Imaginary unmanned cleaning concept; not a real product, verified safety system or operating method.
I see particular value in exploring robotic painting or cleaning where people otherwise face difficult access at height. The proposed benefit is not only output per hour: it may be less direct human exposure to an awkward work location. Painting during construction and cleaning an operating facade belong to different phases, so they should not be treated as one interchangeable deployment case.
That is a candidate benefit, not an established safety or productivity result. Facade geometry, projections, surface conditions, the support arrangement, weather and recovery from a stoppage require equipment-specific assessment. Moving a person away from the working face does not remove preparation, supervision or recovery responsibilities. The illustration is an imaginary cleaning concept, not a certified design, real product or instruction for work at height.
5. Make Task Fit and Human Intervention Explicit
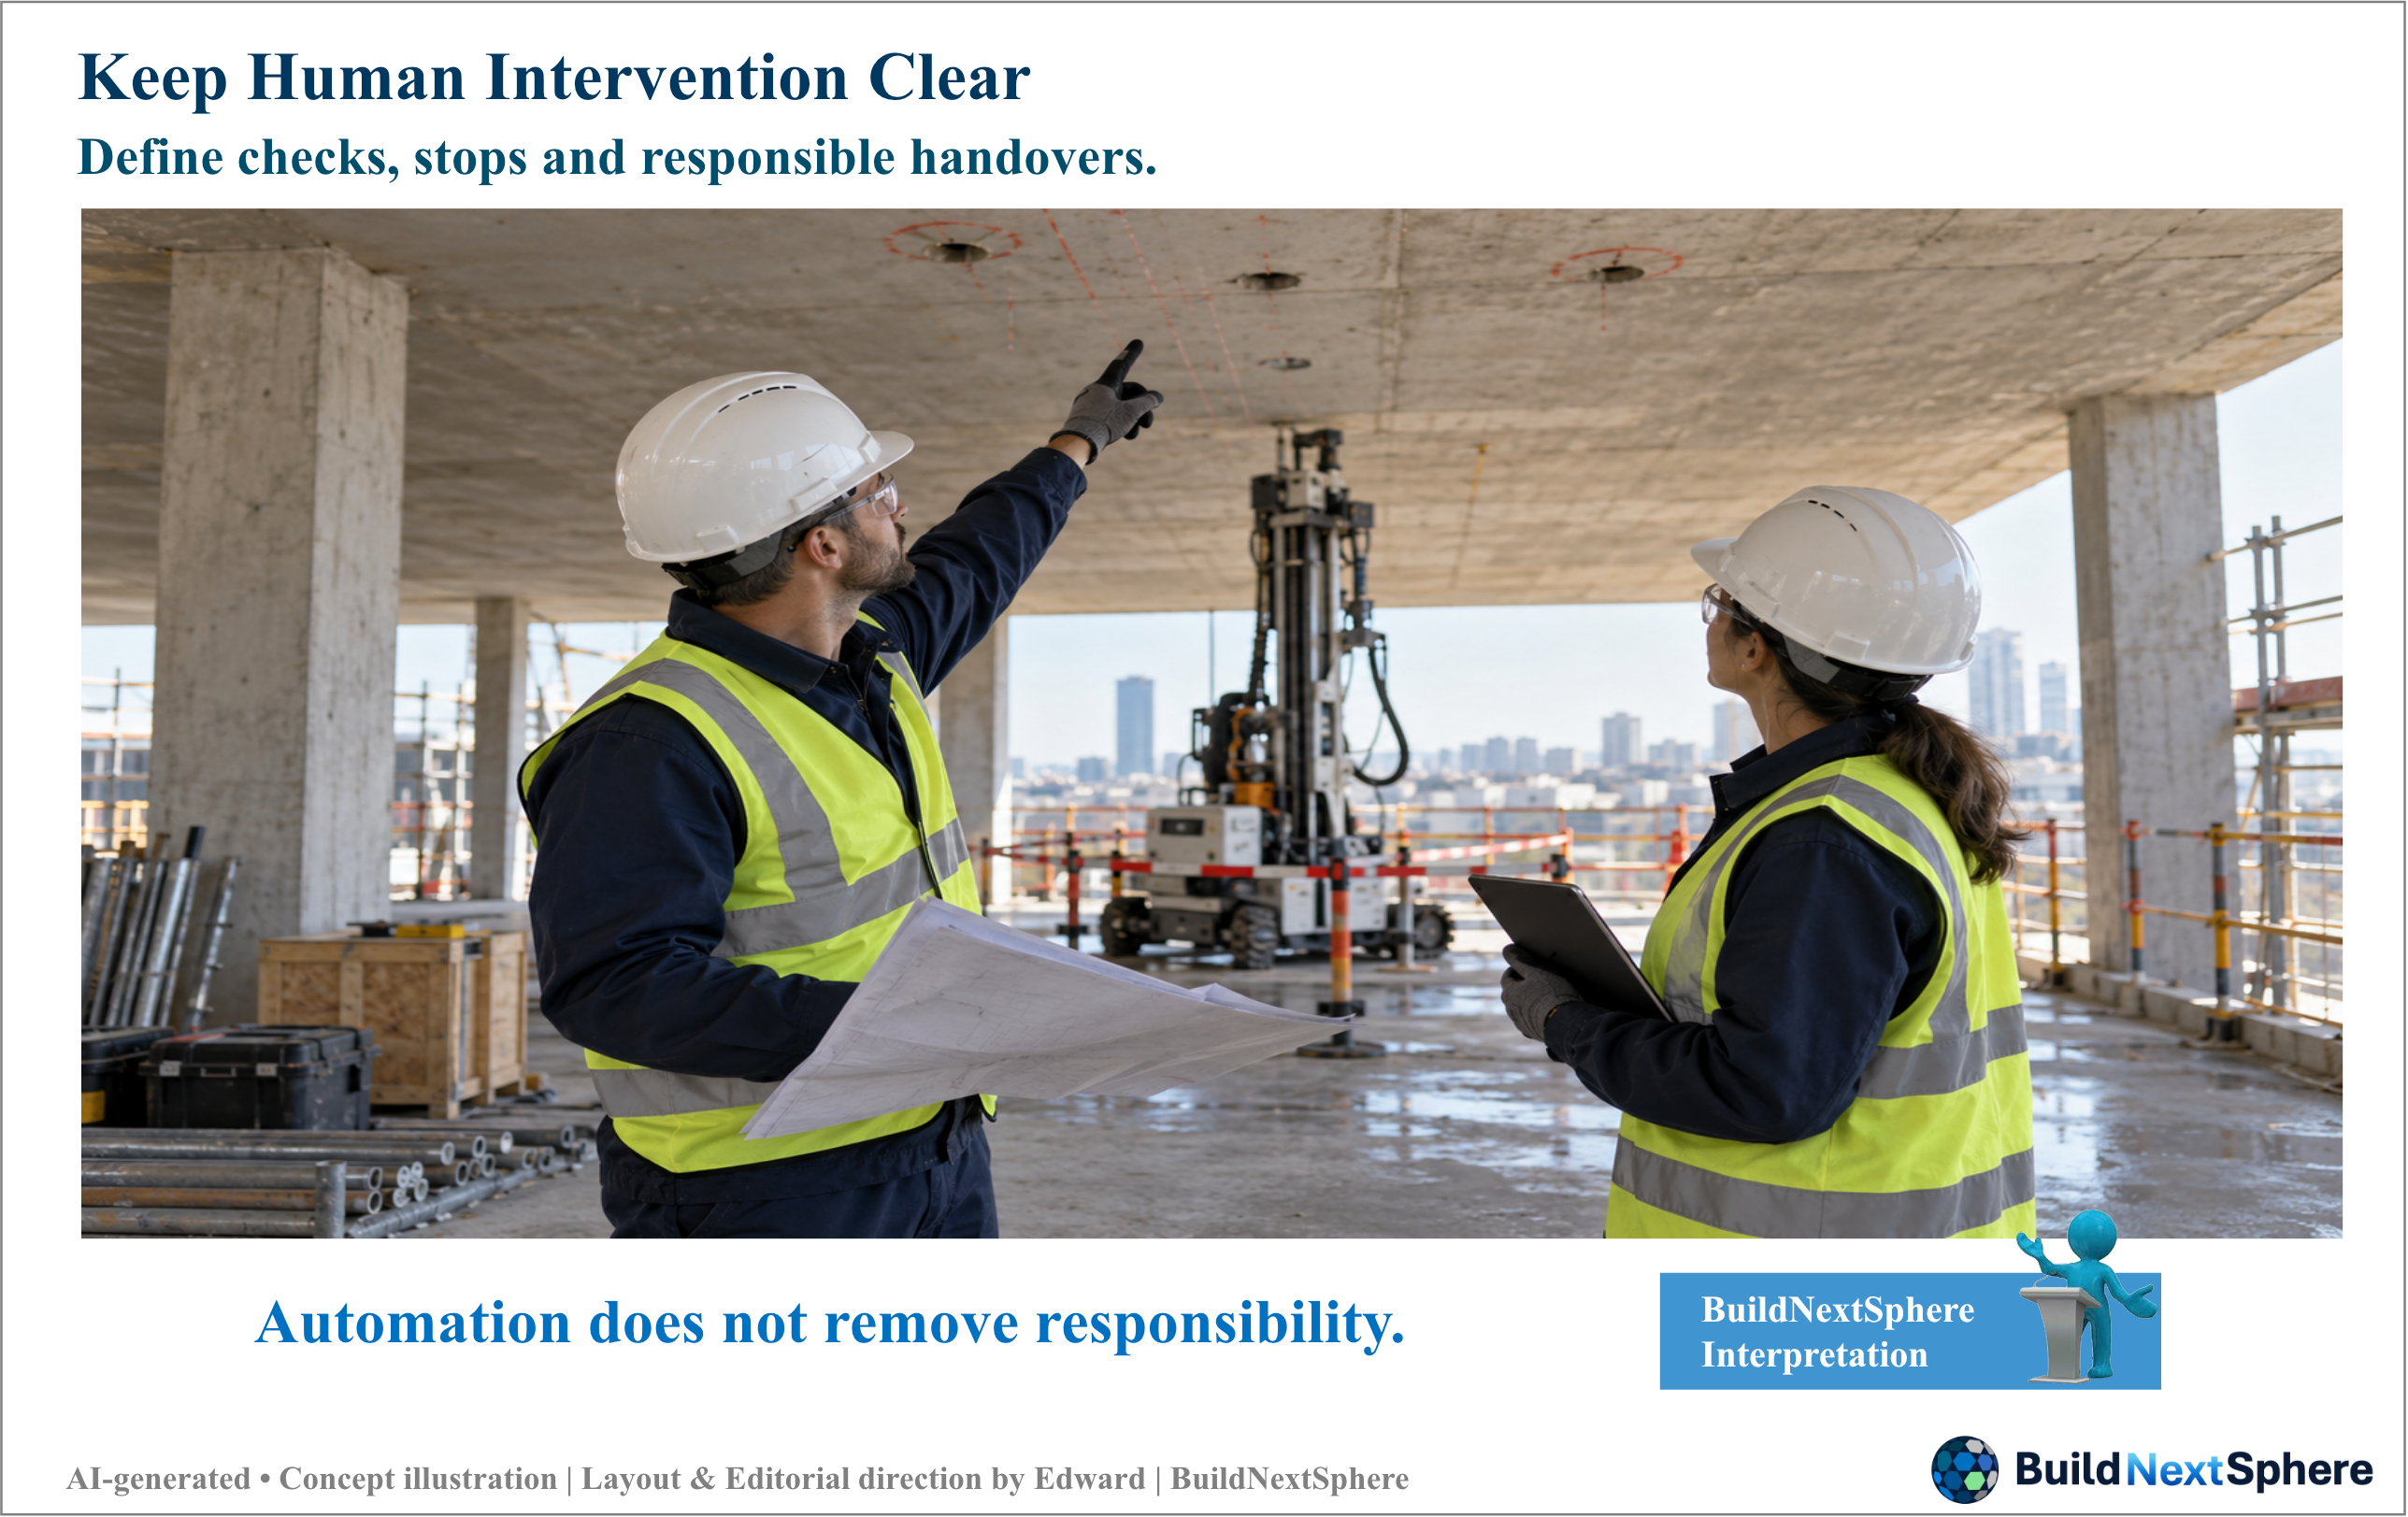
Source: AI-generated concept illustration; layout and editorial direction by Edward Kim | BuildNextSphere.
Note: Hypothetical scene; not Edward’s project, a product demonstration or measured performance evidence.
Use the question sheet below for one bounded task. Its sample entries continue the hypothetical drilling comparison, not a real equipment approval. Replace assumptions with observations and identify the person who will resolve each unknown. The sheet is not a readiness score or a substitute for the applicable quality and safety review.
Human intervention should have a defined purpose: checking input suitability, examining results, resolving exceptions and deciding whether work can resume through the applicable authority. A connected model or work-management record can help convey information; it does not itself authorise physical execution. BNS Architecture is discussed here only as a proposed integration requirement, not an implemented autonomous-control achievement.
One-task fit question sheet
Task boundary
Which planned holes are included, and what remains manual?
Record scope and exclusions; owner to be assigned.
Repeatability
How many comparable holes can be worked continuously?
Area A/B quantities and work windows are unknown.
Changing conditions
Which moves, obstructions and trade interfaces interrupt the task?
Observe workfront availability; do not assume clearance.
Quality verification
Who verifies inputs and accepts the completed holes?
Applicable requirements and reviewer must be confirmed.
Exceptions and handover
Who handles discrepancies, stopping and authorised resumption?
Define responsibilities through project-specific review.
Whole-task burden
What preparation, labour, waiting and correction does the trial require?
Collect baseline and trial evidence separately.
6. Define a Bounded Trial Before Expanding
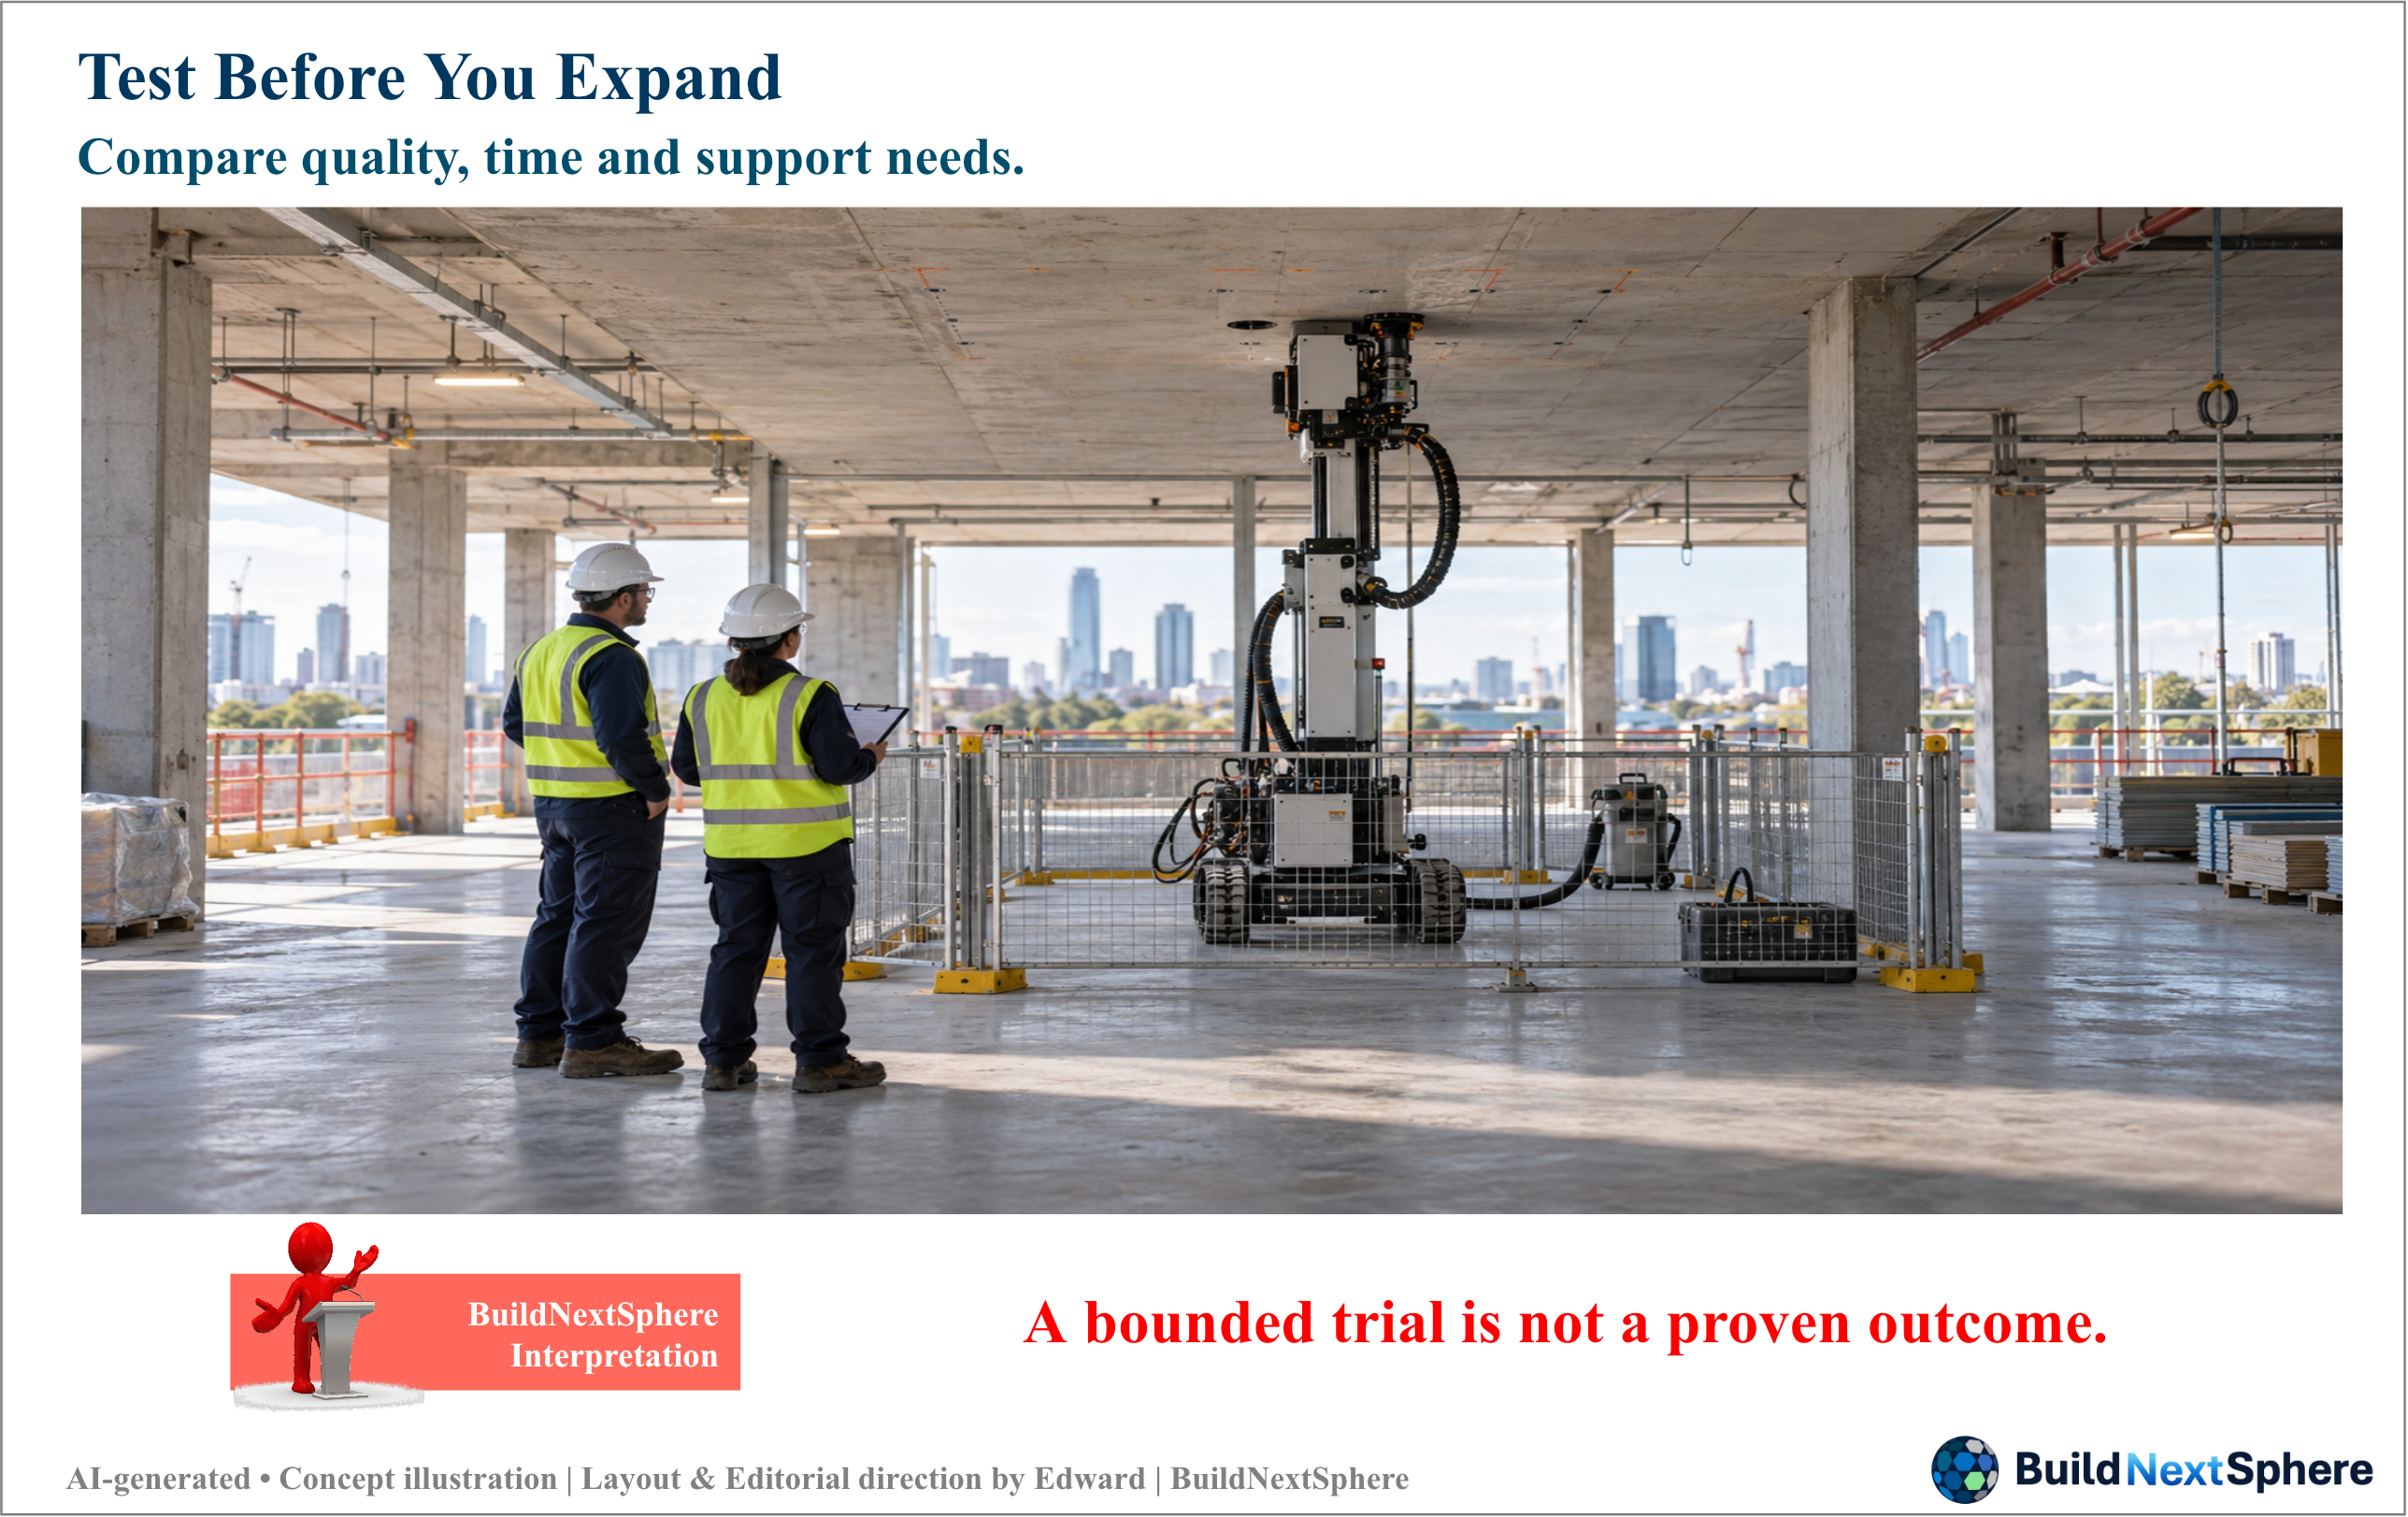
Source: AI-generated concept illustration; layout and editorial direction by Edward Kim | BuildNextSphere.
Note: Hypothetical scene; not Edward’s project, a product demonstration or measured performance evidence.
Choose one task, one work area and a stated comparison period. Agree the required output quality and record the current method before testing an alternative. Observe elapsed time, support labour, preparation, interruptions, correction effort and new risks. Record differences in workload, access and staffing rather than attributing every change to the robot. A limited trial can support expansion, adjustment or stopping.
The useful conclusion is not that construction must become fully autonomous. It is that particular tasks may benefit when their working conditions and human support are understood. Where repetition is difficult to sustain on site, the next question may be whether the work can be reorganised—an issue for the modular and offsite discussion in TEC-04, not proof that every process belongs in a factory. Start with the task you can describe, and test the burden you can observe.
Read the original article on BuildNextSphere
Sources
**S1. **Hilti — Jaibot (28 October 2020)
Ceiling-drilling capability and operator role.
**S2. **Dusty Robotics — FieldPrinter overview
Digital-to-floor layout function.
**S3. **Advanced Construction Robotics — TyBOT
Reported rebar-tying function.
**S4. **Brokk — Demolition robots
Remote-controlled demolition equipment.
**S5. **Dusty Robotics — Coordinating your site and trades
System-specific site and trade coordination; not universal performance evidence.
Sources accessed 12 October 2026; supplier pages rechecked 13 October 2026. Supplier descriptions are used for stated functions, not independently demonstrated project-wide gains.
Basis of This Article
This article combines public supplier descriptions, Edward Kim’s stated perspective and explicitly hypothetical task comparisons. Edward’s direct operation of construction robots and quantified benefits have not been established. The question sheet is an editorial aid, not a certified assessment, operating instruction or procurement recommendation.
Related Reading
Explore more from BuildNextSphere: The Future of Construction: Which Technologies will Really Change the Site? Why Doesn’t Better Technology Always Deliver Better Construction Results? When Projects Don’t Go to Plan: What Are We Missing? Between the Plan and the Site: How Can AI Support Project Execution?
BuildNextSphere
BuildNextSphere connects Development, Technology & Project Intelligence through practical, experience-informed content.
Explore our website for articles and insights, visit our Blogspot blog for more perspectives, and connect with us on LinkedIn for updates and professional discussions.
- Website — buildnextsphere.com
- Blogspot — BuildNextSphere Insights
- LinkedIn — BuildNextSphere
- YouTube — @edwardstories-kr
About the Author
Edward Kim is the Founder of BuildNextSphere.
He draws on his experience with overseas construction projects to share practical insights from field operations, project delivery, and IT-enabled working systems. Through BuildNextSphere, he explores how people, technology, and real project conditions can help turn plans into action and support better project outcomes.
Content & IP Notice
This article and related materials are prepared by BuildNextSphere. Unless otherwise stated, the original structure, wording, diagrams and visual materials are the intellectual property of BuildNextSphere and Edward Kim.
BuildNextSphere, its logo, tagline and brand assets are part of the BuildNextSphere brand identity. Unauthorised reproduction, modification, redistribution or commercial use is not permitted without prior written consent.
Third-party names, technologies and references remain the property of their respective owners. General management principles are not claimed as proprietary inventions.


Comments
Post a Comment